Publications

You can also find my publications on Google Scholar.

C Conference J Journal W Workshop U Under Review

2026
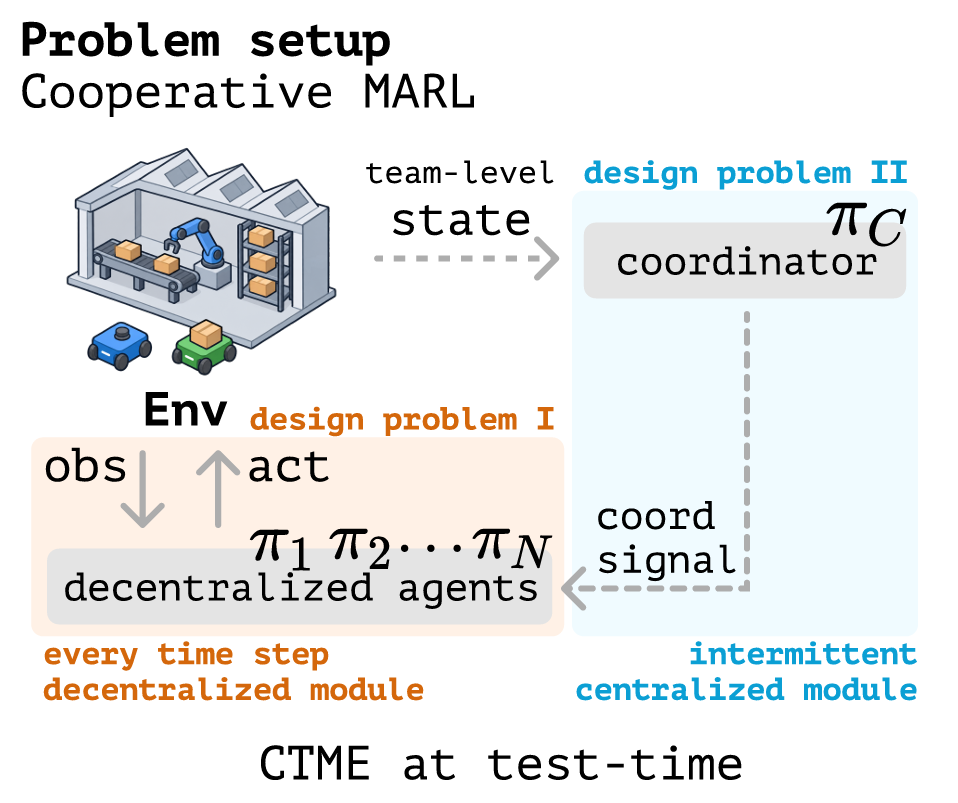
Position: Beyond Training Time, Test-Time Coordination is Essential for Cooperative MARL

C7 Position: Beyond Training Time, Test-Time Coordination is Essential for Cooperative MARL

Dongsu Lee+, Sooraj Sathish+, Joonkyung Kim, Woojun Kim, and Amy Zhang

Conference on Neural Information Processing Systems (NeurIPS) Position Track, 2026

Capability-Aware Heterogeneous Control Barrier Functions for Decentralized Multi-Robot Safe Navigation

U2, W1 Capability-Aware Heterogeneous Control Barrier Functions for Decentralized Multi-Robot Safe Navigation

Joonkyung Kim, Yanze Zhang, Wenhao Luo, and Yiwei Lyu*

Under Review, 2026

IROS 2026 2nd Workshop on Real-World Challenges in Multi-Robot Cooperation (RWCMRC-2)

Best Paper Award

Position: Modular Safety Guardrails Are Necessary for Foundation-Model-Enabled Robots in the Real World

C6 Position: Modular Safety Guardrails Are Necessary for Foundation-Model-Enabled Robots in the Real World

Joonkyung Kim+, Wenxi Chen+, Davood Soleymanzadeh+, Yi Ding, Xiangbo Gao, Zhengzhong Tu, Ruqi Zhang, Fan Fei, Sushant Veer, Yiwei Lyu*, Minghui Zheng*, and Yan Gu*

International Conference on Machine Learning (ICML) Position Track, 2026

Gaussian Mixture-Based Inverse Perception Contract for Uncertainty-Aware Robot Navigation

C5 Gaussian Mixture-Based Inverse Perception Contract for Uncertainty-Aware Robot Navigation

Bingyao Du, Joonkyung Kim, and Yiwei Lyu*

American Control Conference (ACC), 2026

2025

Merry-Go-Round: Safe Control of Decentralized Multi-Robot Systems with Deadlock Prevention

C4 Merry-Go-Round: Safe Control of Decentralized Multi-Robot Systems with Deadlock Prevention

Wonjong Lee, Joonyeol Sim, Joonkyung Kim, Siwon Jo, Wenhao Luo, and Changjoo Nam*

IEEE/RSJ Int. Conf. on Intelligent Robots and Systems (IROS), 2025

CARE: Enhancing Safety of Visual Navigation through Collision Avoidance via Repulsive Estimation

C3 CARE: Enhancing Safety of Visual Navigation through Collision Avoidance via Repulsive Estimation

Joonkyung Kim+, Joonyeol Sim+, Woojun Kim, Katia Sycara, and Changjoo Nam*

Conference on Robot Learning (CoRL), 2025

Escaping Local Minima: Hybrid Artificial Potential Field with Wall-Follower for Decentralized Multi-Robot Navigation

C2 Escaping Local Minima: Hybrid Artificial Potential Field with Wall-Follower for Decentralized Multi-Robot Navigation

Joonkyung Kim, Sangjin Park, Wonjong Lee, Woojun Kim, Hyunga Choi, Nakju Doh, and Changjoo Nam*

Int. Conf. on Robotics and Automation (ICRA), 2025

Safe Interval RRT* for Scalable Multi-Robot Path Planning in Continuous Space

U1 Safe Interval RRT* for Scalable Multi-Robot Path Planning in Continuous Space

Joonyeol Sim, Joonkyung Kim, and Changjoo Nam*

Under Review

2023

Room for me?: Mobile Navigation for Entering a Confined Space Using Deep Reinforcement Learning

C1 Room for me?: Mobile Navigation for Entering a Confined Space Using Deep Reinforcement Learning

Joonkyung Kim and Changjoo Nam*

Int. Conf. on Ubiquitous Robots (UR), 2023